Oct 21 · Startup Connect臺科育成新創交流

THRUST · EFFICIENCY · THERMAL

UAV Propulsion無人機推進

Power SoC and motor drive technology for UAV propulsion.以 Power SoC 與馬達驅動技術,支援無人機推進應用。

ROBICHIP POWER SoC

Our chip. Your propulsion.以自有晶片,串起推進合作。

Choose where we connect.選擇您的合作方向。

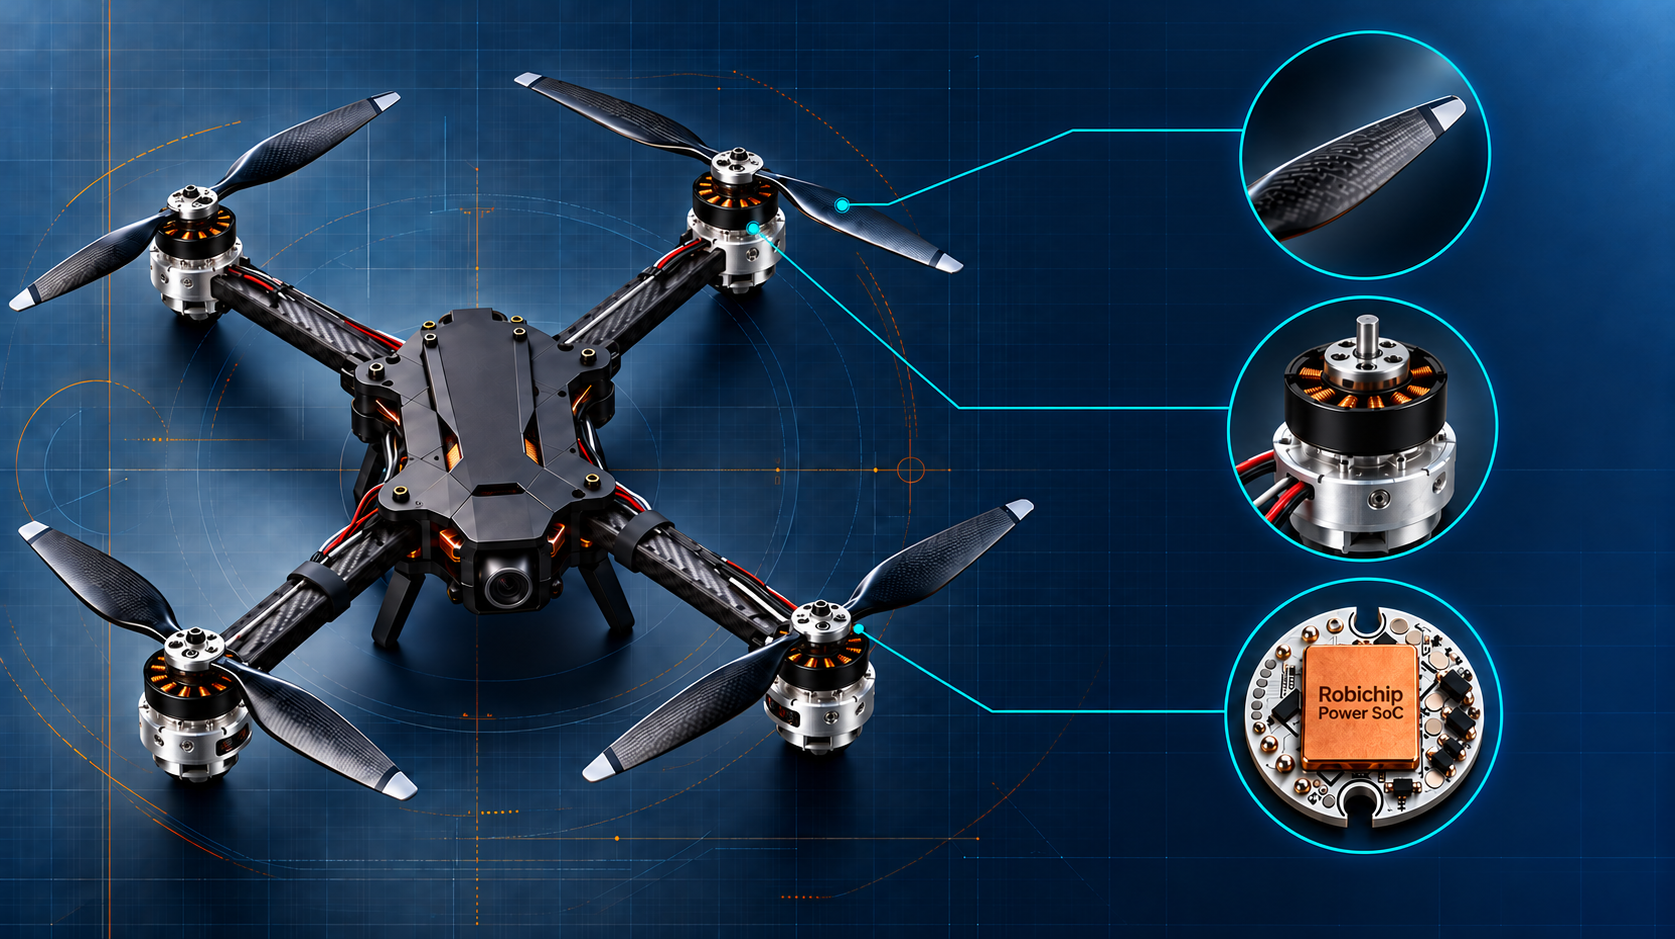
四角鋁製散熱無人機,連結螺旋槳、馬達驅動組合與 RobiChip Power SoC 的放大示意。
Power SoC + Drive RobiChipMotor · Propeller · Assembly Partners / 合作洽談
Explore the components點選元件,探索合作

Select a component. Explore a collaboration.點選元件,展開合作可能。

ROBITHRUST · PRODUCT FAMILY

Configurations & results.MiniE、P、X 規格與工程實測

Published specifications, test configurations and bench results in one place.整合已公布的完整規格欄位、測試配置與台架結果,供選型及工程評估。

Product specifications · 產品規格對照 On small screens, scroll horizontally to compare all three models. / 小螢幕請左右滑動查看三款產品。
Specification · 規格RobiThrust MiniERobiThrust PRobiThrust X
Positioning · 產品定位Light UAV — endurance efficiency and lower weight / 續航效率與減重Premium Type I — large-propeller efficiency and sustained output / 大槳效率與持續輸出Performance UAV — high thrust and dynamic response / 高推力與高動態
Motor · 馬達廠商與型號maxon ECX32 Flat UAVmaxon ECX42 FlatRacing Electric / 六俊電機 RUM-3848Y
Propeller · 螺旋槳配置APC 10 × 4.5MR; up to 11 × 5.5MRP / 可延伸 11 × 5.5MRPFALCON 15 × 6 or 15 × 6E / 或 15 × 6E13–15″ or 10 × 5 tri-blade / 或 10 × 5 三葉槳
Bench supply · 台架測試供電16.8 V24 V44 V
Control core · 控制核心Robichip Power SoCRobichip Power SoCRobichip Power SoC
Driver · 驅動版本RobiDev D or HD (G1/G2)RobiDev D or HD (G1/G2)RobiDev D or HD (G1/G2)
Published thrust · 公布推力Approx. 673 gf @ 6,800 rpm / 約 673 gf1,615 gf @ 5,700 rpm982 gf @ 7,300 rpm
Published efficiency · 公布效率G2 average 11.17 gf/W over 3,100–5,600 rpm / G2 區間平均6.73 gf/W at the reported test point / 公布測試點5.41 gf/W at the reported test point / 公布測試點

Source · 資料來源:RobiThrust product specifications, test data and assembly interfaces, CN / EN, updated 8 October 2026, pp. 1–3. / 中英文技術文件,2026 年 10 月 8 日更新,第 1–3 頁。 Source PDFs下載原始文件

ENGINEERING EVIDENCE · 工程實證

Measured with the configuration in view.保留測試條件,理解每一筆數據。

ENDURANCE · 續航效率

RobiThrust MiniE

11.17gf/W · G2 average / 區間平均

maxon ECX32 Flat UAV · APC 10 × 4.5MR · 16.8 V

Averaging range · 平均工作區間
3,100–5,600 rpm
G2 average · G2 平均效率
11.17 gf/W
Baseline average · 基準平均效率
10.51 gf/W
Maximum measured thrust · 實測最大推力
Approx. 673 gf @ 6,800 rpm / 約 673 gf

The efficiency average and maximum thrust refer to different operating points. / 平均效率與最大推力對應不同工作點。

SUSTAINED OUTPUT · 持續輸出

RobiThrust P

1,615gf · measured thrust / 實測推力

maxon ECX42 Flat · FALCON 15 × 6 · 24 V

Maximum measured thrust · 實測最大推力
1,615 gf @ 5,700 rpm
Measured input power · 實測輸入功率
240 W @ 24 V
Reported-point efficiency · 公布測試點效率
6.73 gf/W
Cooling condition · 散熱條件
Single-side measured / 單側散熱實測

240 W describes the reported bench point, not a continuous power rating. / 240 W 為公布的台架測試點,並非連續額定功率。

DYNAMIC RESPONSE · 高動態

RobiThrust X

982gf · measured thrust / 實測推力

Racing Electric / 六俊電機 RUM-3848Y · 44 V bench / 台架供電

Measured thrust · 實測推力
982 gf @ 7,300 rpm
Reported-point efficiency · 公布測試點效率
5.41 gf/W
Propeller options · 螺旋槳配置
13–15″ or 10 × 5 tri-blade / 或 10 × 5 三葉槳
Evidence scope · 資料範圍
Published performance window / 公布性能工作點

The document lists propeller options without identifying the exact propeller at this measured point. / 文件列有槳型選項,未指明此實測點的確切槳型。

Interfaces & validation組裝介面與驗證範圍

Robichip supplies the Power SoC, RobiDev driver version, and power / thermal interface information. Partners supply motors and propellers; the customer supplies the airframe, battery, cover and final mounting interface.Robichip 提供 Power SoC、RobiDev 驅動版本與電源/熱介面資訊;合作商提供馬達與螺旋槳,客戶提供機體、電池、外罩與最終安裝介面。

  • Mechanical · 機構: Mounting holes, tolerances, propeller clearance, screws and torque / 安裝孔位、公差、槳葉間隙、螺絲與扭矩。
  • Electrical · 電氣: Supply window, polarity, harness, connectors, phase order and rotation / 供電範圍、極性、線束、接頭、相序與旋轉方向。
  • Thermal · 熱管理: Contact surface, mounting orientation, propeller airflow, environment and temperature points / 接觸面、安裝方向、槳流、環境與測溫點。
  • Traceability · 追溯: Motor / propeller lots, board / driver revisions, first-article and EOL records / 馬達與槳批次、板卡與驅動版本、首件與出廠紀錄。

Dimensions, weight, continuous ratings and environmental limits are not specified in these documents; confirm them for the selected configuration during Design-in.本文件未提供尺寸、重量、連續額定值與環境限制,需於 Design-in 階段依選定配置確認。

TECHNICAL DOCUMENTS · 技術文件

Keep the full engineering reference.中英文 PDF 規格書下載

Both editions include MiniE, P and X specifications, bench data, figures and assembly interfaces. / 兩種語言版本均收錄三款產品規格、實測數據、圖表與組裝介面。

Chinese PDF下載中文規格書中文 · 3 pages / 頁 · 24.2 MBEnglish PDF下載英文規格書English · 3 pages · 24.0 MB

START A DESIGN-IN CONVERSATION · 開始設計導入

Build the UAV Propulsion case around evidence.以實證建立無人機推進案件。

Start with the system, constraint or validation question. RobiChip will help identify the useful scope before a case is opened.從系統、限制條件或驗證問題開始;案件啟動前,先界定最有效的合作範圍。